


Scheme research and design of the ultrasonic range measurement system
#ultrasonic
#range measurement
#non-contact
#distance sensor
#automation
#robotics
#industrial application
#liquid level measurement
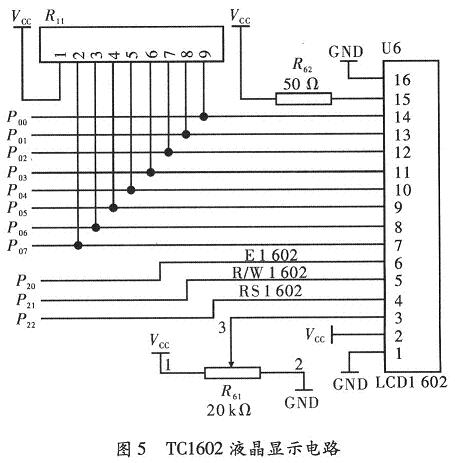
Description: In daily life and production, many situations such as vehicle rollback, robot obstacle avoidance, industrial well logging, and liquid level measurement in reservoirs require non-contact automatic distance measurement. Ultrasonic waves refer to sound waves produced by machinery in an elastic medium at frequencies greater than 20 kHz. They possess characteristics such as high directivity, low energy dissipation, and relatively long propagation lengths, making them suitable for non-contact distance measurement. Ultrasonic waves are insensitive to light, color, and electromagnetic fields, providing better adaptability to various environments. Additionally, ultrasonic measurement is precise and cost-effective. This article proposes utilizing the AT89S52 microcontroller as the core component, employing a pair of 40 kHz piezoelectric ultrasonic transducers to design a compact, low-cost, high-precision ultrasonic rangefinder with temperature compensation, real-time LCD display, and alarm functions. Ultrasonic transducers can be classified into mechanical and electrical types, functioning as energy converters. The design employs piezoelectric transducers that utilize the crystalline properties of piezoelectric materials. The transducer consists of two piezoelectric crystal plates and a diaphragm. When an alternating pulse signal is applied to the two electrodes, the frequency corresponds to the inherent oscillation frequency of the piezoelectric crystal, causing resonance that drives the diaphragm to produce ultrasonic waves. Conversely, when no voltage is applied, the diaphragm can receive ultrasonic waves and convert mechanical energy back into electrical signals, functioning as an ultrasonic receiver. In the ultrasonic circuit, the transmitter outputs a series of pulse rectangular waves; the greater the pulse width, the more energy is transmitted, allowing for longer distance measurements. There are slight differences in the structures of ultrasonic transmitting transducers and echo microphones, which should be noted during usage. Various ultrasonic ranging methods exist, including detection methods, phase detection methods, and round-trip time detection methods. The design adopts the round-trip time detection method, where an ultrasonic transducer emits ultrasonic waves of a certain frequency that travel through the air, reflect off an object, and return to the receiver. The time taken for this round trip is measured, and the distance can be calculated based on the speed of sound. If the distance to the target is denoted as s and the measured time as t, the relationship can be expressed as s = vt/2, where v represents the speed of ultrasonic propagation. For high accuracy, factors such as temperature affecting ultrasonic propagation speed must be considered, necessitating adjustments to minimize errors. The system comprises hardware components, including transmission, backwave signal reception, temperature measurement, display, alarm, and ultrasonic power supply, along with corresponding software. A systematic functional block diagram illustrates the design.
The proposed ultrasonic rangefinder system is designed to operate efficiently in a variety of environments, utilizing the properties of ultrasonic waves for accurate distance measurement. The core of the system, the AT89S52 microcontroller, serves as the brain of the operation, facilitating signal processing and control of the ultrasonic transducers. The choice of 40 kHz piezoelectric transducers is critical, as this frequency strikes a balance between effective range and resolution, making it suitable for various applications.
The piezoelectric transducers function in both transmitting and receiving modes. During transmission, the microcontroller generates a pulse signal that excites the piezoelectric elements, causing them to vibrate and emit ultrasonic waves. The diaphragm's movement produces sound waves that propagate through the air. Upon encountering an object, these waves reflect back to the transducer, where they induce a voltage in the piezoelectric material, allowing the system to detect the distance based on the time delay of the received signal.
Temperature compensation is an essential feature of the design, as the speed of sound in air varies with temperature. A temperature sensor integrated into the system measures ambient conditions, allowing the microcontroller to adjust calculations accordingly, ensuring accurate distance measurements across different environments.
The LCD display provides real-time feedback to the user, showcasing the measured distance and any alerts if the distance exceeds predefined thresholds. The alarm function can be programmed to notify users of critical distances, enhancing safety in applications such as vehicle proximity detection and industrial automation.
Overall, this ultrasonic rangefinder system is a compact, cost-effective solution that leverages modern microcontroller technology and piezoelectric principles to deliver precise distance measurement capabilities in a wide range of applications.In the daily life and production, a lot of occasions such as car roll back, robot avoid hindering, industrial well logging, liquid level measurement of the reservoir etc. to need to carry on the range finding of non-contact automatically. Supersonic wave refers to the frequency the machinery produced in the elastic medium greater than 20 kHz shakes the wave, it have the intersection of
directivity and strong, energy dissipation slowly the intersection of propagation length and characteristic such as being relatively far, often used for the range finding of non-contact. Because supersonic wave is insensitive to light, color and electromagnetic field, there is better adaptive capacity on environment in ultrasonic range finding, in addition ultrasonic measurement when real, precision, but also price can trade off well.
For this reason, try to regard one-chip computer AT89S52 as the core in the article, utilize a pair of 40 kHz piezo-electric ultrasonic transducers to design a section of minor volume, cheap, precision great, having temperature compensation, real-time LCD revealing and warning ultrasonic ranger. The ultrasonic static divides two kinds into machinery way and electricity way, it is actually a kind of changer, convert acoustic energy, on the contrary receiving end to electric energy or mechanical energy in the intersection of transmitting terminal and it.
Design the ultrasonic static to adopt the piezoelectric type ultrasonic transducer in the electric way this time, it makes use of crystalline syntony of piezoelectricity to work. It has two piezo-electric crystal plates and a sound board. When its extra pulse signal of the two poles, its frequency means the inherent oscillating frequency of the piezo-electric crystal plate, the resonance will take place in the piezo-electric crystal plate, and will drive the sound board to shake and produce supersonic wave.
On the contrary, if two inter-electrode not applied voltage, when the sound board has received supersonic wave, will oppress the piezo-electric crystal plate to shake, change the mechanical energy into the electric signal, become the ultrasonic receiver. In the ultrasonic circuit, the transmitting terminal outputs a series of pulse rectangular wave, the greater impulse width is, the more the number outputted is, the greater energy is, the farther the distance that can examine is.
Have difference slightly on ultrasonic transmitting transducer and its structure of the echo microphone, should distinguish the sign on the device while using. There is multi-type in the ultrasonic range finding method: Such as detecting method, phase place detecting method, detecting method of the amplitude of acoustic wave of round trip time.
Originally design adopting the range finding of the detecting method of round trip time. Its principle is that an ultrasonic static launches the supersonic wave of certain frequency, travel through air medium, reach and measure the goal or obstacle, reflect back, by the received pulse of the ultrasonic receiver after reflection, the time namely round trip time gone through by it, round trip time relates to distance of the travelling journey of supersonic wave. It is tested that transmission time can obtain the distance. Assume s gets to examine the distance from the appearance for the testee, the time to measure is t/ s, the ultrasonic propagation velocity is that v/ m s- 1 represents, there is a relational expression 1 In case of great of accuracy requirement, need to consider the impact on ultrasonic propagation velocity of the temperature, pressing type 2 Revise the ultrasonic propagation velocity, in order to reduce the error.
This system is formed by hardware circuit parts such as transmitting, back wave signal receive, thermometry, revealing and calling the police, power of supersonic wave, etc. and corresponding software part. Systematic functional block diagram, as shown in Fig
The proposed ultrasonic rangefinder system is designed to operate efficiently in a variety of environments, utilizing the properties of ultrasonic waves for accurate distance measurement. The core of the system, the AT89S52 microcontroller, serves as the brain of the operation, facilitating signal processing and control of the ultrasonic transducers. The choice of 40 kHz piezoelectric transducers is critical, as this frequency strikes a balance between effective range and resolution, making it suitable for various applications.
The piezoelectric transducers function in both transmitting and receiving modes. During transmission, the microcontroller generates a pulse signal that excites the piezoelectric elements, causing them to vibrate and emit ultrasonic waves. The diaphragm's movement produces sound waves that propagate through the air. Upon encountering an object, these waves reflect back to the transducer, where they induce a voltage in the piezoelectric material, allowing the system to detect the distance based on the time delay of the received signal.
Temperature compensation is an essential feature of the design, as the speed of sound in air varies with temperature. A temperature sensor integrated into the system measures ambient conditions, allowing the microcontroller to adjust calculations accordingly, ensuring accurate distance measurements across different environments.
The LCD display provides real-time feedback to the user, showcasing the measured distance and any alerts if the distance exceeds predefined thresholds. The alarm function can be programmed to notify users of critical distances, enhancing safety in applications such as vehicle proximity detection and industrial automation.
Overall, this ultrasonic rangefinder system is a compact, cost-effective solution that leverages modern microcontroller technology and piezoelectric principles to deliver precise distance measurement capabilities in a wide range of applications.In the daily life and production, a lot of occasions such as car roll back, robot avoid hindering, industrial well logging, liquid level measurement of the reservoir etc. to need to carry on the range finding of non-contact automatically. Supersonic wave refers to the frequency the machinery produced in the elastic medium greater than 20 kHz shakes the wave, it have the intersection of
directivity and strong, energy dissipation slowly the intersection of propagation length and characteristic such as being relatively far, often used for the range finding of non-contact. Because supersonic wave is insensitive to light, color and electromagnetic field, there is better adaptive capacity on environment in ultrasonic range finding, in addition ultrasonic measurement when real, precision, but also price can trade off well.
For this reason, try to regard one-chip computer AT89S52 as the core in the article, utilize a pair of 40 kHz piezo-electric ultrasonic transducers to design a section of minor volume, cheap, precision great, having temperature compensation, real-time LCD revealing and warning ultrasonic ranger. The ultrasonic static divides two kinds into machinery way and electricity way, it is actually a kind of changer, convert acoustic energy, on the contrary receiving end to electric energy or mechanical energy in the intersection of transmitting terminal and it.
Design the ultrasonic static to adopt the piezoelectric type ultrasonic transducer in the electric way this time, it makes use of crystalline syntony of piezoelectricity to work. It has two piezo-electric crystal plates and a sound board. When its extra pulse signal of the two poles, its frequency means the inherent oscillating frequency of the piezo-electric crystal plate, the resonance will take place in the piezo-electric crystal plate, and will drive the sound board to shake and produce supersonic wave.
On the contrary, if two inter-electrode not applied voltage, when the sound board has received supersonic wave, will oppress the piezo-electric crystal plate to shake, change the mechanical energy into the electric signal, become the ultrasonic receiver. In the ultrasonic circuit, the transmitting terminal outputs a series of pulse rectangular wave, the greater impulse width is, the more the number outputted is, the greater energy is, the farther the distance that can examine is.
Have difference slightly on ultrasonic transmitting transducer and its structure of the echo microphone, should distinguish the sign on the device while using. There is multi-type in the ultrasonic range finding method: Such as detecting method, phase place detecting method, detecting method of the amplitude of acoustic wave of round trip time.
Originally design adopting the range finding of the detecting method of round trip time. Its principle is that an ultrasonic static launches the supersonic wave of certain frequency, travel through air medium, reach and measure the goal or obstacle, reflect back, by the received pulse of the ultrasonic receiver after reflection, the time namely round trip time gone through by it, round trip time relates to distance of the travelling journey of supersonic wave. It is tested that transmission time can obtain the distance. Assume s gets to examine the distance from the appearance for the testee, the time to measure is t/ s, the ultrasonic propagation velocity is that v/ m s- 1 represents, there is a relational expression 1 In case of great of accuracy requirement, need to consider the impact on ultrasonic propagation velocity of the temperature, pressing type 2 Revise the ultrasonic propagation velocity, in order to reduce the error.
This system is formed by hardware circuit parts such as transmitting, back wave signal receive, thermometry, revealing and calling the police, power of supersonic wave, etc. and corresponding software part. Systematic functional block diagram, as shown in Fig
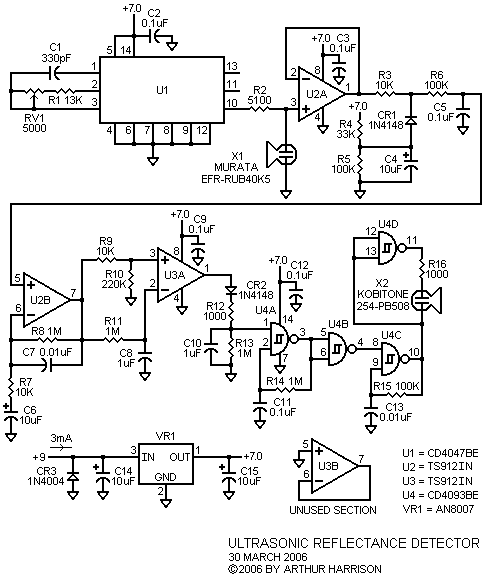
Ultrasonic Reflectance Detector
This circuit detects motion within approximately 5 inches of a piezo-ceramic element ultrasonic transducer. The detection distance is much smaller than obtainable with other ultrasonic techniques; however, it only requires a single transducer, as opposed to the two-transducer arrangement typically...
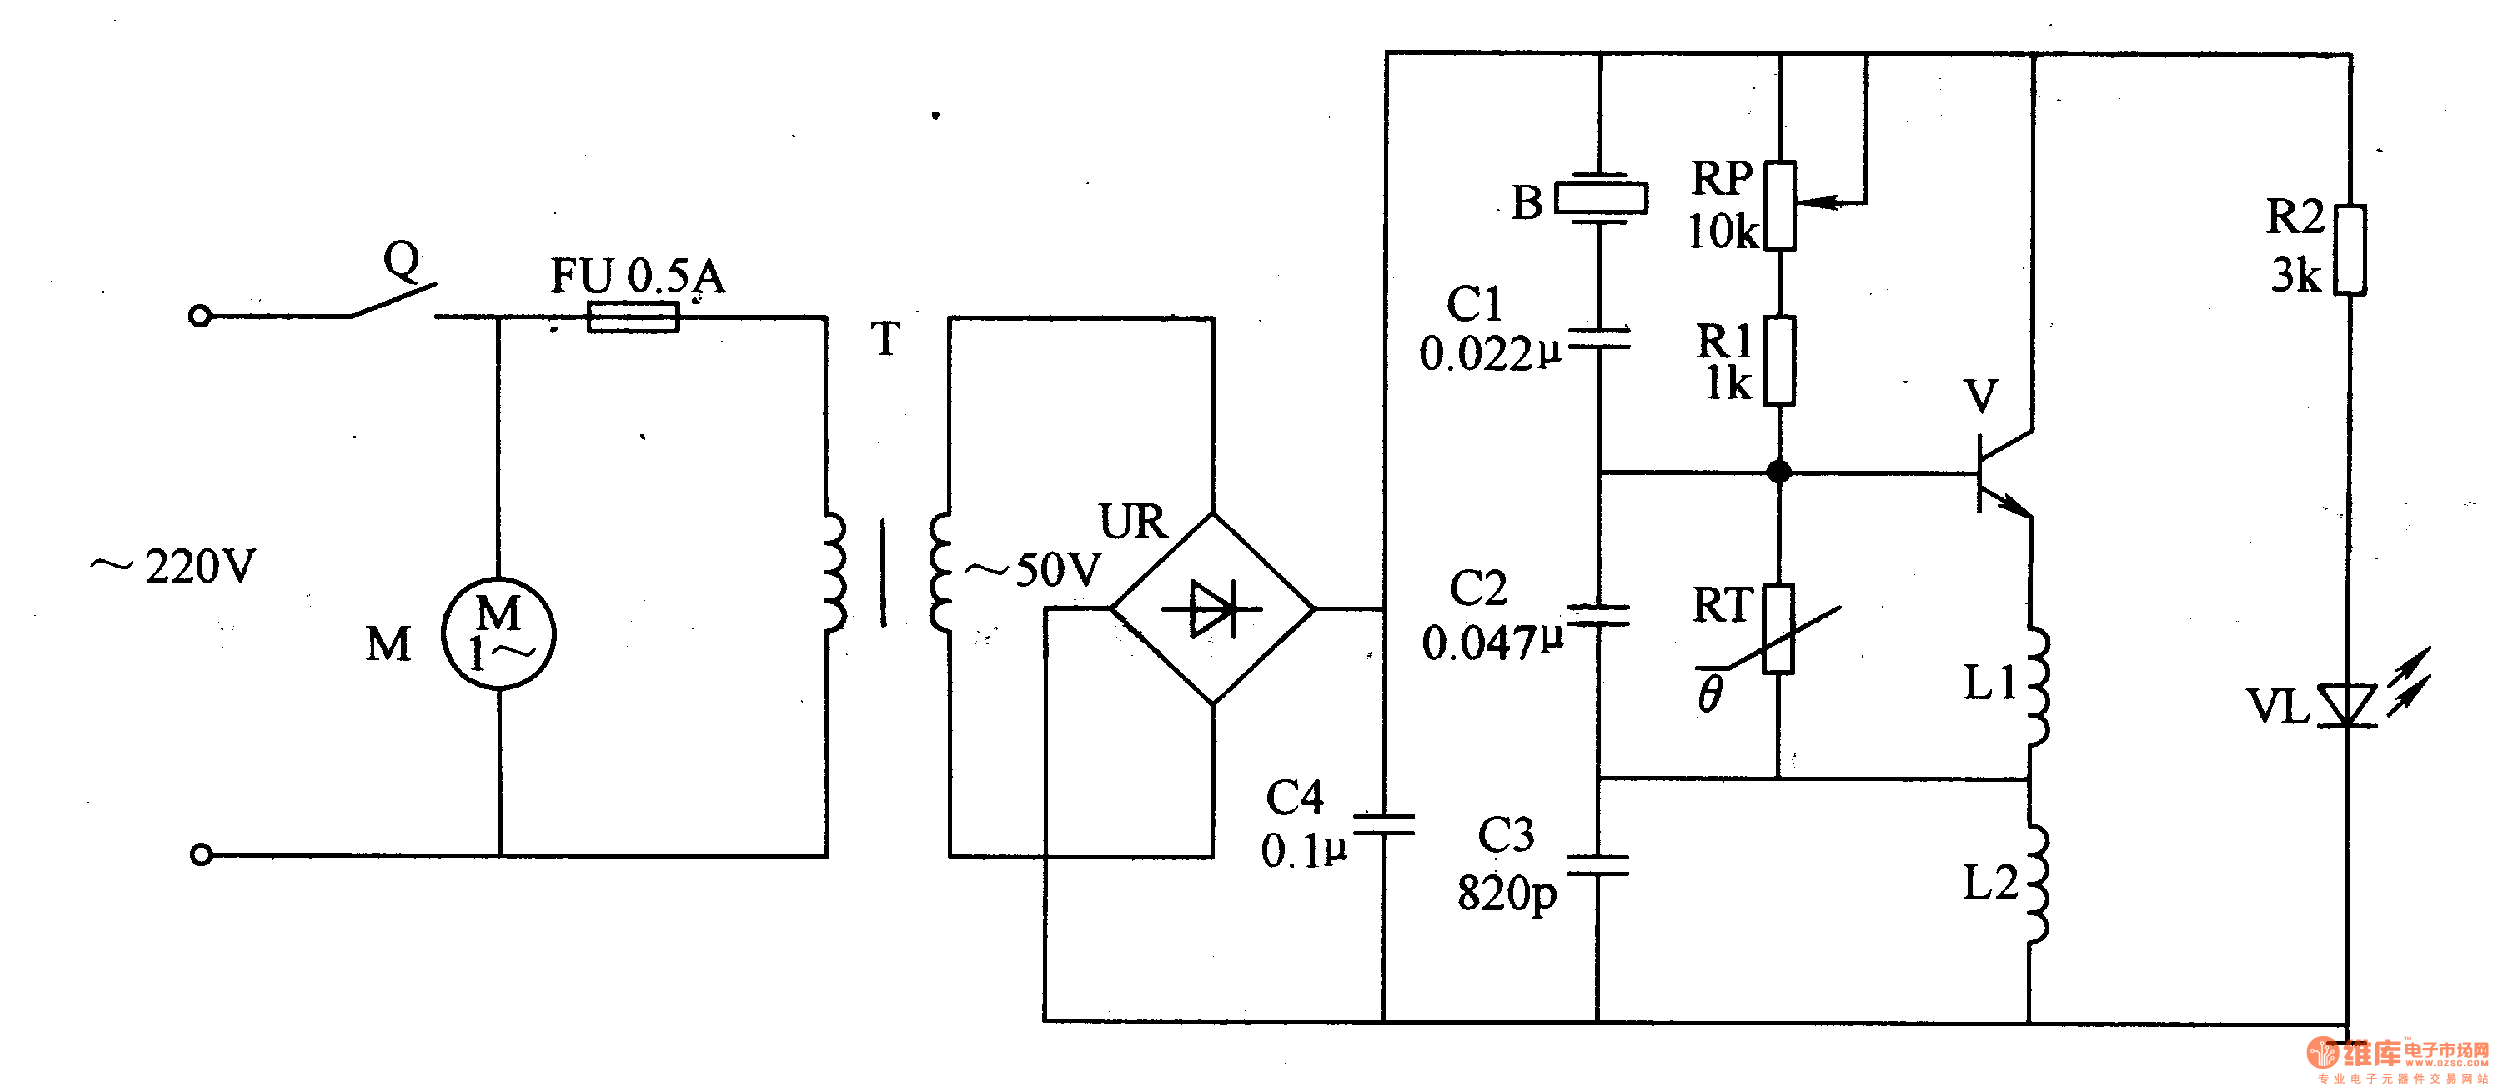
Medical ultrasonic atomizer 1
The medical ultrasonic atomizer circuit consists of a power supply circuit, an ultrasonic oscillator, and an atomizer circuit, as illustrated in figure 9-110. The power supply circuit includes a timer (Q), a fuse (FU), a current transformer (T), bridge rectifiers...
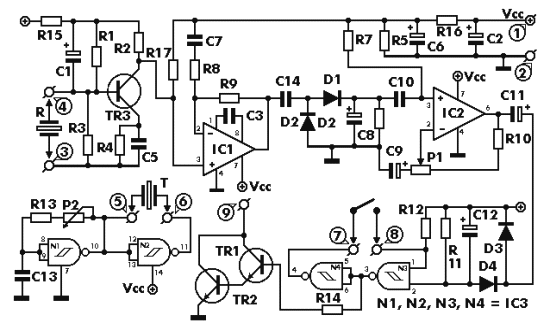
Ultrasonic Radar AlarmCircuit Project
The circuit consists of an ultrasonic transmitter and a receiver that operate at the same frequency. Ultrasonic piezoelectric transducers serve as the output and input devices, respectively, with their frequency of operation determined by the specific devices used. The transmitter...
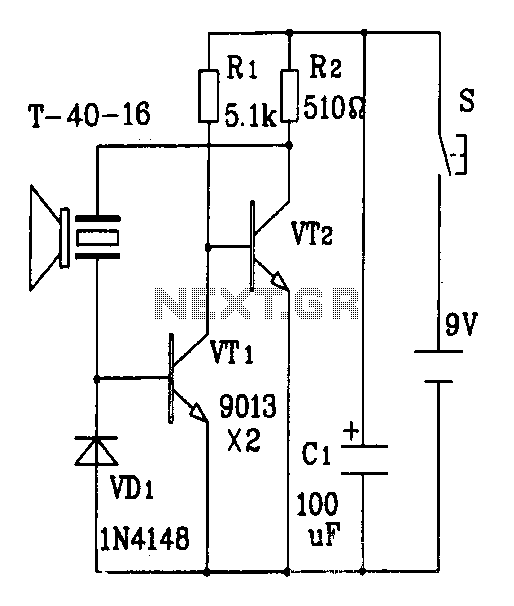
An ultrasonic transmitter circuit diagram discrete components
The discrete components ultrasonic transmitter circuit T/R-40-16 can emit a series of ultrasonic signals at a frequency of 40 kHz. This circuit operates at a voltage of 9V and has a current consumption of 25mA, with a control distance of...
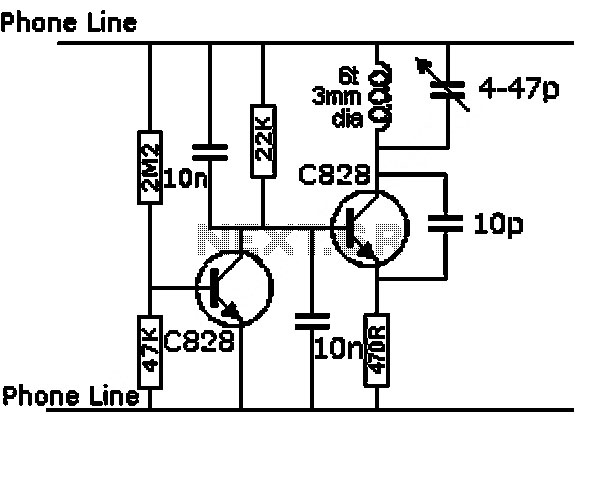
Ultrasonic Radar
This project presents a practical application in security and alarm systems for homes, shops, and vehicles. It consists of a set of ultrasonic receivers and transmitters operating at the same frequency. The design features an ultrasonic radar circuit. The circuit...
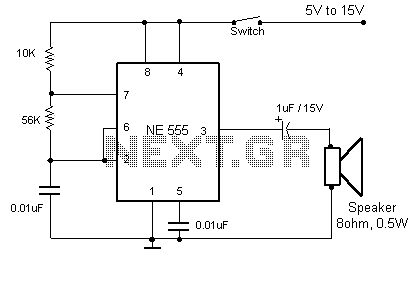
ultrasonic switch sensor
This circuit operates using ultrasonic sound, which is sound at frequencies above 20 kHz, making it inaudible to humans. The circuit generates ultrasonic sound frequencies between 40 kHz and 50 kHz. Similar to other remote control systems, this circuit includes...
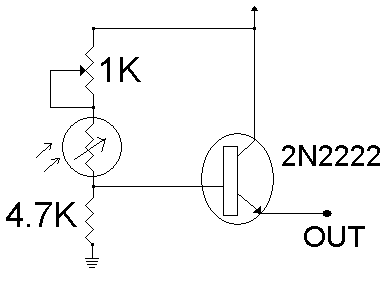
Robotics Art
This page contains links to various projects and items of interest for the RoboticsArt Studio class projects.
The RoboticsArt Studio class projects encompass a range of innovative endeavors that integrate art and robotics. These projects typically involve the design, assembly, and...
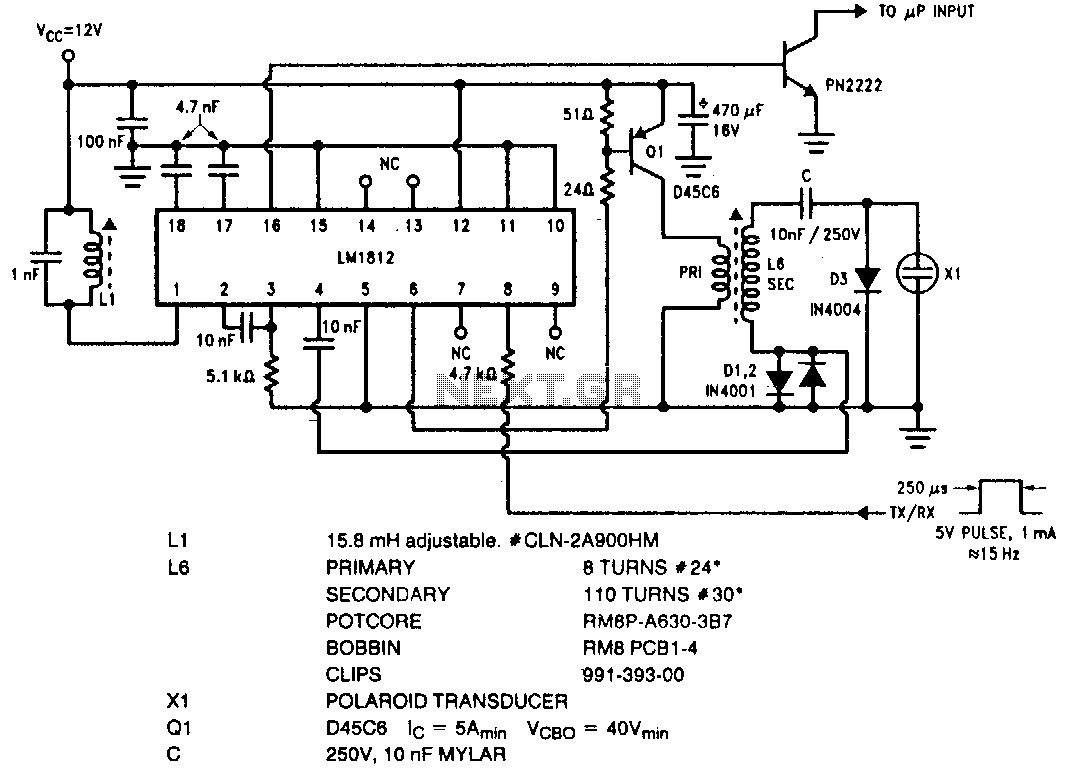
Ultrasonic-transceiver
The LM1812 is a complete ultrasonic transceiver integrated circuit designed for various pulse-echo ranging applications. The chip functions by transmitting a burst of oscillations through a transducer, which is then used to listen for a return echo. If an echo...
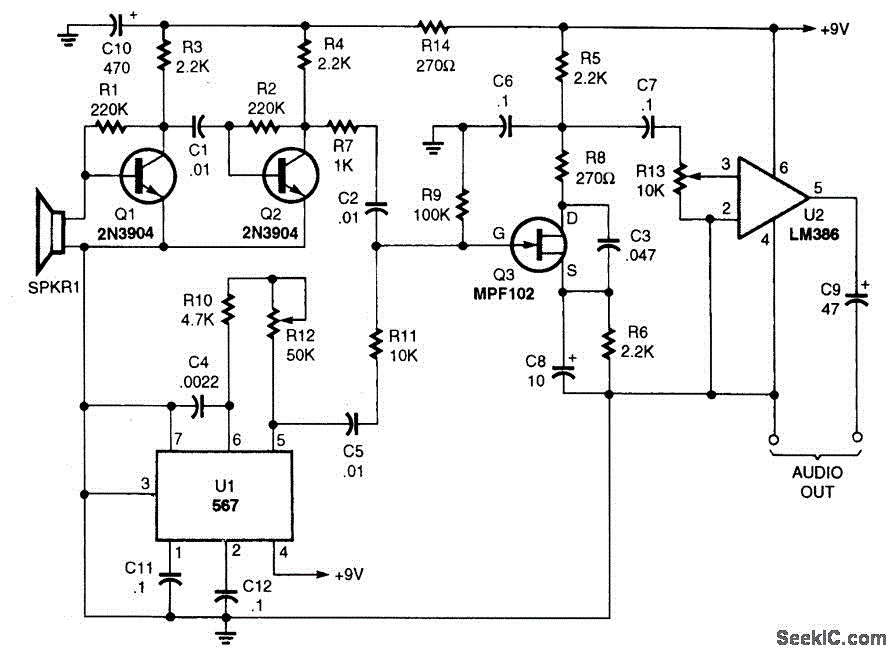
ULTRASONIC SOUND RECEIVER
The performance of this sensitive ultrasonic receiver is impressive. It allows users to listen to various sources of ultrasonic sounds, including bugs, bats, and engines. The circuit utilizes a piezo tweeter as an ultrasonic microphone, with amplifier stages Q1 and...